General-purpose home robots won’t succeed by trying to learn everything—they must excel at a narrow slice of high-value tasks first.
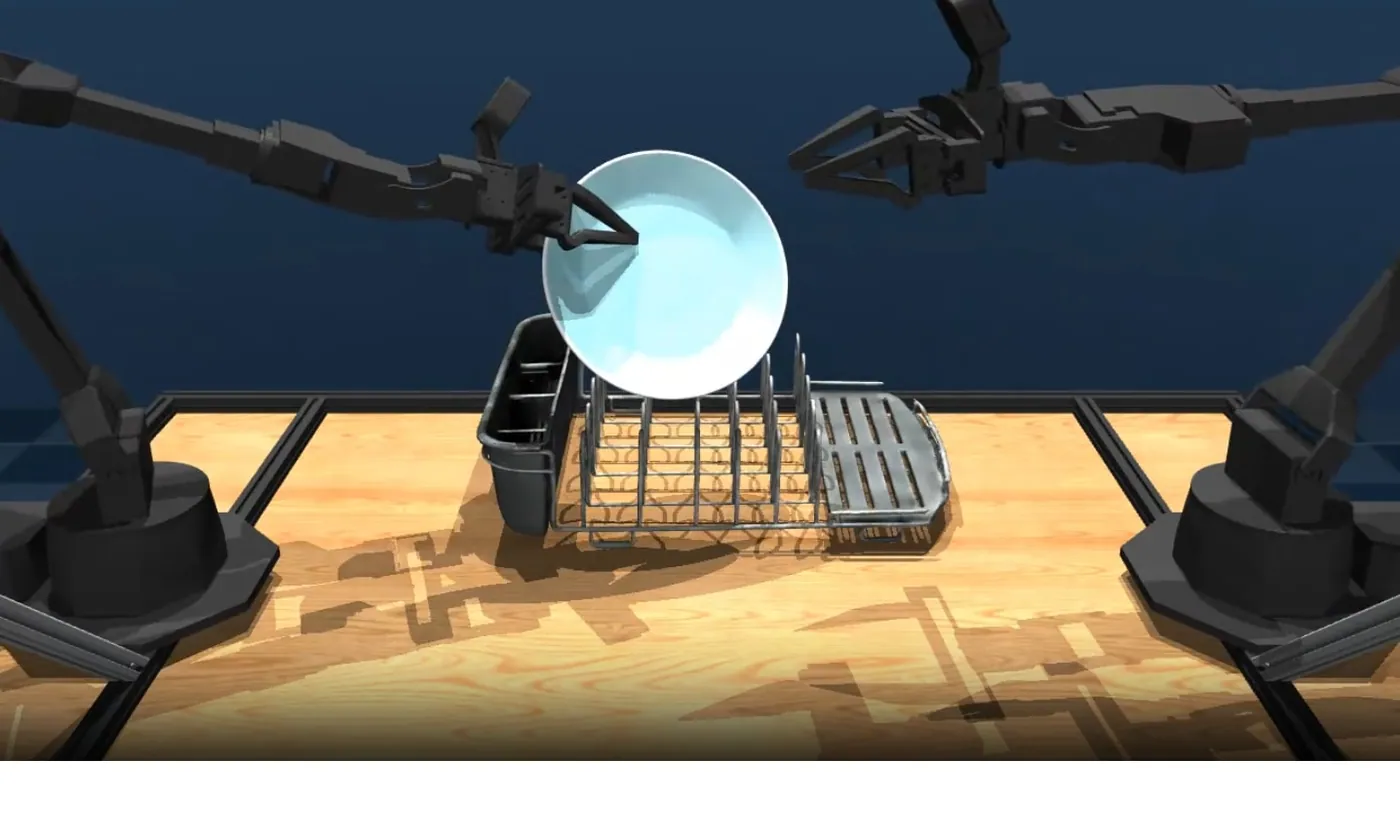
The Stanford Mobile ALOHA approach shows why: by collecting 25k tele-op demos in a single kitchen domain, researchers achieved 86% success on bimanual chores that stump larger “do-it-all” models.
The next leap requires collaboration with real housekeepers, nurses, and tradespeople who can record expert workflows, label failure modes, and iterate rapid fine-tunes.
Our roadmap:
- Pick one service niche with clear ROI (e.g., laundry folding)
- Capture rich multimodal demonstrations
- Train modular diffusion or ACT policies per skill
- Chain them with a lightweight task planner
Focus beats breadth—and gets robots solving real chores sooner.